
WorldIndustrialWeekly Smart Manufacturing: Edge AI Brings Fault Detection to the Line
For SmartManufacturing teams, the useful next step in maintenance is not another dashboard; it is placing inference where the machine already generates signals. Local analytics can turn raw vibration, current, and temperature readings into events or shutdown triggers, reducing the amount of data that must travel through the plant network. In practice, embedded monitoring typically combines sensors, DC/DC converters, and other signal-conditioning circuits with MCUs or processors and communication interfaces. This guide uses two embedded examples—one from Microchip and one from Texas Instruments—to show how model-based diagnostics can support real-time monitoring at the machine side.
From the Control Room to the Machine Side
Centralized monitoring remains useful for supervision, but the physical factory floor imposes constraints. When hundreds of machines share a network, raw high-frequency data can overwhelm communications and add delay. Processing near each asset distributes inference, reduces dependence on continuous connectivity, and allows faults to be recognized sooner. Lower latency is important because vibration signals, motor currents, and temperature are high-frequency measurements; sending them continuously over a centralized industrial network can overload bandwidth and increase latency.
- Scalability: Inference nodes can sit close to individual assets, easing expansion in plants where hundreds of machines create heavy communications overhead.
- Deterministic response: Fault detection and the matching response can happen closer to the control loop, preserving deterministic timings while revealing abnormal behavior quickly.
- Network resilience: Local decision-making reduces reliance on the network for fault processing and on internet connectivity, so offline operation can last longer.
- Bandwidth and storage: Only high-level information is sent to central systems, so bandwidth and storage needs can be much lower.
- Privacy and security: Keeping sensitive information in the local device reduces the chance of data breaches and cyber threats.
Model Choices for Edge AI
When fault detection and inference are built on AI models, system robustness can improve greatly. Training can target high-accuracy inference over many fault conditions. These models can operate in cloud servers or on edge devices.
Historically, cloud AI computing has been the more typical choice because larger models demand substantial computing capability and are often confined to servers. Edge AI has gained strength as smaller, more efficient models appear and embedded MCUs and processors gain performance.
In contrast with cloud servers, edge AI hardware must operate continuously in harsh settings, including vibration and high temperatures. Choosing hardware involves balancing speed, low-power capability, size, memory capacity, and computational performance. MCUs with AI support provide deterministic real-time operation, which makes sampling and control-loop timing predictable. A further option is smart sensors that embed AI chips; such devices can watch sensor data, run embedded AI algorithms, diagnose issues, and produce fault alerts.
Embedded AI is generally built on machine learning. Models learn patterns and produce inferences that enable accurate anomaly detection. Decision trees, support-vector machines, and random forests are common model types. Deep learning is a subset of machine learning that relies on artificial neural networks. It can address complex patterns but needs more computational and memory resources.
Example 1: DC Arc Detection on a Digital-Signal Controller
Arc faults may arise from power spikes, insulation degradation along the power transmission path, degradation in semiconductor devices or passive components used for power conversion, and load failures. These faults create safety hazards for personnel and equipment. Different applications have distinct arc signatures, such as arcs from an electric-vehicle battery disconnect versus arcs from a solar inverter.
DC power transmission has expanded notably in recent years. Solar energy generation and EV charging stations illustrate DC power generation and load. In contrast with AC systems, DC arc faults lack zero-crossing, so they can be self-sustaining. Series DC arcs in solar panels, formed along a single conductor wire, may be difficult to detect because they produce only a small drop in overall current amid load fluctuations.
A challenge for useful ML models of DC arcs is the scarcity of widely available datasets. Customer arc datasets are proprietary and are usually not shared by embedded controller manufacturers. One way to test the ML toolchain is to use the publicly available IEEE low-voltage DC arc datasets, which Microchip Technology Inc. uses in its arc fault-detection reference design.
Microchip’s dsPIC33 digital-signal controllers provide a digital-signal processing engine and integrated high-performance peripherals such as analog-to-digital controllers, supporting precision motor control, digital power conversion, and advanced sensing. Within that family, the dsPIC33A is Microchip’s most advanced series. The DSC includes a 32-bit CPU capable of 200-MHz operation, a high-speed DSP engine for single-cycle multiply-accumulate instructions in numerical processing, and a double-precision floating-point unit for math operations.
High-speed peripherals include a 12-bit ADC capable of up to 40 mega samples per second (MS/s), 100-MHz gain-bandwidth op amps, 5-ns comparators, and 1-MS/s digital-to-analog converters. Where a general-purpose MCU uses multistep interrupt service routines, the dsPIC33 uses a single-step ISR with context register switching to save critical context. This compresses a typical 20-instruction ISR to four to six instructions and enables low interrupt latency.
Together, the fast ISR response and 200-MHz operation reduce interrupt latency to less than 0.18 µs, versus 0.4 µs for a general-purpose MCU running at 120 MHz. That enables quicker response to time-critical tasks such as real-time arc fault detection and system shutdown.
Software development support is critical when deploying MCU hardware in real-time applications. Microchip’s MPLAB ML development suite converts raw sensor data in both time and frequency domains into statistically meaningful features. Those features train and evaluate multiple algorithms to identify the best-performing model. The suite supports model training, validation, and optimization, and can generate a C API that runs on the MCU.
With the IEEE DC arc datasets, MPLAB ML trained a model in just 13 minutes. The decision-tree-based model generated for the dsPIC33A DSC was highly efficient: a size of only 1,142 bytes, utilizing 1,336 bytes of SRAM and 4,522 bytes of flash. It achieved a latency of 0.6584 ms with 100% accuracy on the DC arc dataset. By comparison, a rules-based series fault-inference approach achieved only 57% accuracy. A reference design based on the dsPIC33AK128MC102 DSC is available.
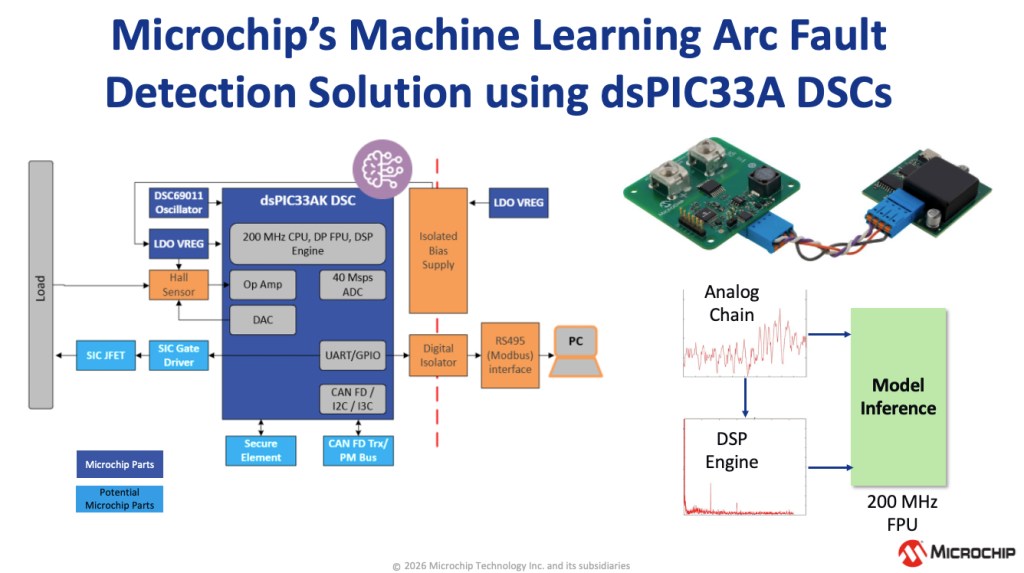
Figure 1: The arc-fault reference design from Microchip combines IEEE low-voltage DC arc datasets with MPLAB ML to produce a compact decision-tree model that reaches 100% accuracy. Source: Microchip Technology Inc.
Example 2: Gearbox Anomaly Detection with an NPU Inside an MCU
A neural processing unit, or NPU, is a specialized hardware accelerator tuned for neural-network computations. Although less flexible than a DSP engine, NPUs can deliver better speed/performance/power tradeoffs for DL models that need extensive matrix-multiplication operations, such as convolutional neural network-based AI inference. Placing an NPU inside an MCU offloads computationally intensive tasks from the main CPU to the NPU, improving inference speed while reducing power consumption.
Texas Instruments Inc.’s MSPM0G5187 MCU includes a TinyEngine NPU integrated into a CPU based on a 32-bit Arm Cortex M0+ core. This NPU can perform 640–2,560 mega operations per second on pretrained CNN models. It has been shown to use 120× less energy per inference and have 90× lower latency than software-based AI.
TI’s CCStudio Edge AI Studio offers a graphical environment for model development, training, and compilation. Besides the pretrained models in the TI Model Zoo, developers can bring their own models or train models with custom data. Its neural-network compiler converts trained ML models into optimized C code for the specific hardware and enables seamless deployment to either the NPU or CPU.
TI has demonstrated edge AI analytics with the MSPM0G5187 MCU for gearbox fault detection. By monitoring vibration patterns through sensors and applying ML algorithms to detect anomalies, industrial systems such as gearboxes and motors can move toward predictive rather than reactive maintenance. 1D CNNs are highly effective for time-domain analysis of sensor data such as vibration patterns.
The vibration dataset used for the model was generated with SpectraQuest’s Gearbox Fault Diagnostics Simulator. It contains recordings from four sensors placed in four different directions, with the load varying from 0% to 90%. This open-source dataset covers both healthy and broken-tooth gearboxes. Eight trained models were created to run on the MCU using the vibration dataset. As Figure 2 illustrates, the optimized AI-based model reaches 99.9% accuracy versus traditional rules-based detection.
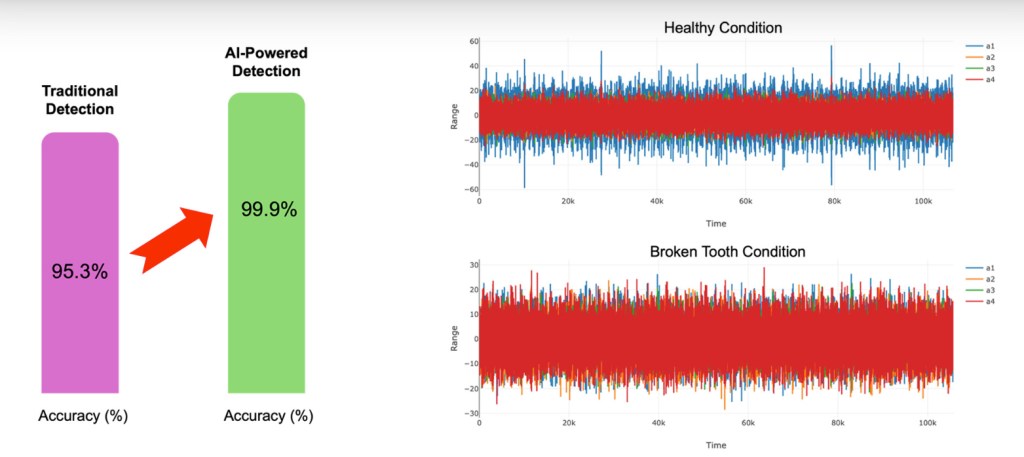
Figure 2: The TI gearbox fault detection example uses CCStudio Edge AI Studio and vibration-based ML, reaching 99.9% accuracy on an optimized model versus rules-based detection. Source: Texas Instruments Inc.
Implementation Path for Smart Manufacturing Teams
- Map the asset class: DC power paths, solar or EV installations, gearboxes, motors, or other production-line equipment where local detection is valuable.
- Define the fault signature before model training: arc events, vibration patterns, temperature deviations, or current anomalies need clear sample rates and response criteria.
- Choose the local computing node: an MCU or DSC, a processor with AI support, or a smart sensor that can diagnose and alert.
- Collect or access representative data. Public options such as the IEEE low-voltage DC arc datasets can test a toolchain, while proprietary customer datasets often remain unavailable.
- Train and evaluate with a toolchain. Platforms such as MPLAB ML or CCStudio Edge AI Studio support feature conversion, algorithm comparison, validation, optimization, C code generation, or model compilation.
- Deploy with deterministic constraints in mind: confirm sample timing, interrupt latency, memory, flash, SRAM, and communication overhead remain acceptable.
- Send only high-level results to central systems when feasible, so bandwidth, storage, and network dependence stay manageable.
- Connect alerts, shutdown commands, and asset health reports to maintenance workflows so production teams can act without waiting for a cloud round trip.
Selection Checklist for Edge Inference Hardware
| Option | Best fit | Key benefit | Design question |
|---|---|---|---|
| DSC or MCU with AI support | Precision motor control, digital power conversion, and advanced sensing | Deterministic real-time operation and predictable sampling and control-loop timing | Do interrupt latency and response time fit the fault being monitored? |
| NPU inside an MCU | DL models that require extensive matrix multiplication, such as CNN inference | Better speed, performance, and power tradeoffs through offloading | Can the compiled model deploy to the NPU or CPU as needed? |
| Smart sensor | Compact local diagnosis and alert generation | Watches sensor data, runs embedded AI algorithms, and produces fault alerts | Does the sensor support the required algorithm and communication interface? |
| Centralized or cloud AI | Larger models and broader training workflows | High computing capability for models confined to servers | Can the network carry raw data without overload, latency, or outage risk? |
Common Misconceptions
- All AI belongs in the cloud. Cloud AI has been more typical because larger models demand substantial computing capability, but smaller, more efficient models and stronger embedded MCUs make edge AI practical.
- Plant networks can always carry raw high-frequency data. Vibration, motor current, and temperature data can overload a centralized industrial network, increase latency, and reduce resilience when connections fail.
- DC arcs are easy to spot because current falls sharply. Some series DC arcs, especially in solar panels, produce only a small drop amid load fluctuations and lack zero-crossing, so they can be self-sustaining.
- Threshold rules are enough. In the arc example, the decision-tree model achieved 100% accuracy on the dataset, while a rules-based series fault-inference approach achieved 57% accuracy.
- Edge means less analytics. Edge devices can host feature extraction, trained models, and inference while central systems still receive high-level information.
FAQ
Q: What problems does edge AI solve for industrial maintenance?
A: It supports lower latency, higher accuracy, and quicker action for real-time monitoring, while reducing bandwidth use and network dependence and improving privacy or security.
Q: Which signals are most useful for local analysis?
A: Vibration patterns, motor currents, temperature, and power-path signatures are common because they can reveal abnormal behavior near the asset.
Q: What model families are mentioned in the examples?
A: Decision trees, support-vector machines, and random forests are typical ML models; deep learning includes neural-network approaches, and the gearbox case highlights 1D CNNs for time-domain vibration data.
Q: Can teams start without proprietary data?
A: Partially. Public datasets can test a toolchain, as seen with the IEEE low-voltage DC arc datasets and the open-source vibration dataset from SpectraQuest’s Gearbox Fault Diagnostics Simulator. Customer arc datasets, however, are often proprietary and not shared.
Action Recommendation
Start with a narrow pilot on one asset type where a local fault event can trigger a clear response. Use representative data, train and validate with an embedded AI toolchain, and compare model performance with existing rules. When the pilot meets timing, memory, latency, and accuracy constraints, expand to additional nodes so production teams can act without relying on continuous connectivity. For reference designs and examples already shown, Microchip’s arc approach is built around the dsPIC33AK128MC102, and TI’s gearbox detection uses the MSPM0G5187 with CCStudio Edge AI Studio.